
ROB-460 · Lesson 6 of 12 · 30 min
Marine and underwater robots
The ocean covers about 70 percent of the Earth's surface, and most of it has never been observed in detail. Robots are the main way that scientists, energy companies, navies and governments work below the surface: they inspect pipelines and cables, map the seabed, monitor ocean properties for climate research, maintain offshore wind farms, inspect aquaculture pens, find wrecks and recover objects. Water changes almost everything about robotics. Radio and GNSS do not penetrate it, light fades within tens of meters, pressure rises by about one atmosphere every 10 m, and currents push vehicles around. This lesson covers the main vehicle types, the physics of buoyancy and propulsion, underwater navigation and communication, applications and the emerging rules for autonomous vessels.
Vehicle types
Remotely operated vehicles (ROVs) are tethered to a ship or platform by an umbilical that carries power and high-bandwidth data, so a pilot can fly the vehicle with live video and operate manipulators. Work-class ROVs weighing several metric tons do construction and repair on offshore oil and gas and wind installations; observation-class ROVs inspect hulls, dams and fish farms. Autonomous underwater vehicles (AUVs) carry their own batteries and follow pre-planned missions, typically surveying the seabed with sonar and cameras, then surfacing or docking to deliver data. Underwater gliders change their buoyancy to sink and rise, using wings to convert vertical motion into slow forward motion; at around 0.3 m/s they are slow, but they can operate for months on small batteries. Profiling floats such as those of the international Argo program drift at depth and rise every ten days to measure temperature and salinity, with roughly 4,000 floats active worldwide. Uncrewed surface vehicles (USVs), including wind- and solar-powered sailing drones, carry sensors at the surface for months and can relay communications for underwater vehicles.
| Vehicle | Power and link | Typical endurance and speed | Typical uses |
|---|---|---|---|
| Work-class ROV | Umbilical power and fiber-optic data | Unlimited while tethered; about 1 m/s | Offshore construction, intervention, recovery |
| Observation ROV | Tether | Hours; 0.5 to 1 m/s | Hull, dam, net-pen and tank inspection |
| AUV | Onboard battery; acoustic link while submerged | 10 to 70 hours; 1 to 2.5 m/s | Seabed mapping, pipeline survey, mine countermeasures |
| Glider | Small battery; satellite at surface | Weeks to months; about 0.3 m/s | Ocean observation along transects |
| Profiling float | Battery; satellite at surface | Years; drifts with currents | Global temperature and salinity profiles |
| Uncrewed surface vehicle | Diesel, battery, solar or wind; satellite link | Days to months | Survey, monitoring, communication relay |
Hybrid and resident systems blur these categories. Hybrid ROVs can operate tethered or autonomously, and resident vehicles live on the seabed at docking stations near offshore fields, charging and uploading data there and carrying out inspections without a support ship, which reduces costs and emissions from vessel time.
Buoyancy, drag and thrust
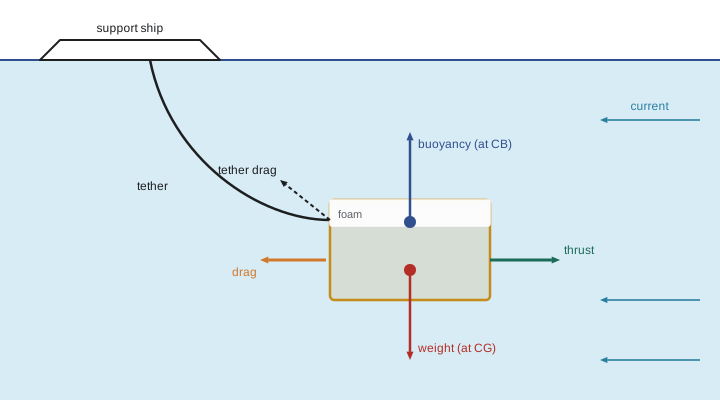
Underwater vehicles are usually trimmed to be slightly positively buoyant, so that if power fails they float slowly to the surface. Archimedes' principle gives the buoyant force as the weight of displaced water: \( F_b = \rho_w g V \), with seawater density about 1,025 kg/m³. The vehicle's net vertical force is buoyancy minus weight. Syntactic foam, a composite of hollow glass microspheres in resin, provides buoyancy that resists crushing at depth. Ballast and trim weights adjust buoyancy and keep the center of buoyancy above the center of gravity, which gives passive stability in roll and pitch.
Hydrodynamic drag rises with the square of speed, \( F_d = \tfrac{1}{2} \rho C_d A v^2 \), so the power needed rises with the cube of speed. That is why AUVs are streamlined torpedo shapes with low drag coefficients and cruise slowly, and why ROVs, which are boxy open frames carrying tools, need large thrusters even at modest speeds. Currents add directly to the relative water speed, so a vehicle designed to hold station in a 1 m/s current needs far more thrust than one that only has to move in still water.
# Sizing horizontal thrust for an observation ROV holding station in a current
rho = 1025.0                 # seawater density, kg/m^3
def drag(cd, area, v):
    return 0.5 * rho * cd * area * v**2
vehicle = dict(cd=1.0, area=0.30)          # open frame, frontal area in m^2 (illustrative)
tether = dict(cd=1.2, diameter=0.012)      # 12 mm tether
for current in (0.25, 0.5, 0.75, 1.0):
    for depth in (50, 150):
        f_vehicle = drag(vehicle["cd"], vehicle["area"], current)
        # crude tether model: treat a length equal to depth as broadside to the current
        f_tether = drag(tether["cd"], tether["diameter"] * depth, current)
        total = f_vehicle + f_tether
        print(f"current {current:4.2f} m/s depth {depth:3d} m: vehicle {f_vehicle:6.1f} N, "
f"tether {f_tether:6.1f} N, total {total:6.1f} N ({total/9.81:5.1f} kgf)")current 0.25 m/s depth 50 m: vehicle 9.6 N, tether 23.1 N, total 32.7 N ( 3.3 kgf) current 0.25 m/s depth 150 m: vehicle 9.6 N, tether 69.2 N, total 78.8 N ( 8.0 kgf) current 0.50 m/s depth 50 m: vehicle 38.4 N, tether 92.2 N, total 130.7 N ( 13.3 kgf) current 0.50 m/s depth 150 m: vehicle 38.4 N, tether 276.8 N, total 315.2 N ( 32.1 kgf) current 0.75 m/s depth 50 m: vehicle 86.5 N, tether 207.6 N, total 294.0 N ( 30.0 kgf) current 0.75 m/s depth 150 m: vehicle 86.5 N, tether 622.7 N, total 709.2 N ( 72.3 kgf) current 1.00 m/s depth 50 m: vehicle 153.8 N, tether 369.0 N, total 522.8 N ( 53.3 kgf) current 1.00 m/s depth 150 m: vehicle 153.8 N, tether 1107.0 N, total 1260.8 N (128.5 kgf)
Doubling the current quadruples the drag, and in this example the tether adds more drag than the vehicle itself, three to seven times as much depending on depth. Real tether analysis uses catenary models and current profiles, but this rough calculation explains why small ROVs struggle in tidal channels and why deep work-class systems use a tether management system: a cage or garage lowered on a heavy armored umbilical, from which the ROV flies on a short, light tether.
Worked problem
Trimming an AUV for positive buoyancy
An AUV displaces 0.120 m³ of seawater and weighs 121.0 kg in air. Engineers want it to be 0.5 kg positively buoyant. How much ballast must be removed or foam added?
Show solution
- Buoyant mass equivalent: \( 1025 \times 0.120 = 123.0 \) kg.
- Current net buoyancy: \( 123.0 - 121.0 = 2.0 \) kg positive.
- To reach 0.5 kg positive, add \( 2.0 - 0.5 = 1.5 \) kg of ballast (removing foam would also work).
Answer: The AUV is 2.0 kg positive, so add about 1.5 kg of ballast; in fresh water (density 1,000 kg/m³) the same vehicle would be about 1 kg negative, so trim must be redone when moving between fresh and salt water.
Worked problem
Pressure at depth
What is the absolute pressure on a housing at 3,000 m depth, and what force acts on a 0.15 m diameter flat camera port?
Show solution
- Hydrostatic pressure: \( \rho g h = 1025 \times 9.81 \times 3000 \approx 30.2 \) MPa, plus 0.1 MPa atmospheric, about 30.3 MPa.
- Port area: \( \pi (0.075)^2 \approx 0.0177 \) m².
- Force: \( 30.3 \times 10^6 \times 0.0177 \approx 536 \) kN.
Answer: About 30 MPa, roughly 300 times atmospheric pressure, giving over 500 kN on a small port; this is why deep housings use thick titanium, glass spheres or pressure-tolerant oil-filled electronics.
Navigation without GNSS
Submerged vehicles cannot receive GNSS, so they combine dead reckoning with acoustic positioning. A Doppler velocity log (DVL) measures velocity over the seabed by bouncing acoustic beams off the bottom, typically within a range of tens to a few hundred meters; combined with an inertial navigation system and a pressure depth sensor, it limits drift to a fraction of a percent of distance traveled with high-grade systems. Ultra-short baseline (USBL) positioning uses a transceiver on the ship to measure range and bearing to a beacon on the vehicle, giving positions tied to the ship's GNSS; long baseline (LBL) systems use several transponders placed on the seabed and give higher accuracy over a work site. AUVs often surface periodically for a GNSS fix, or receive USBL updates by acoustic link. Terrain-relative navigation matches sonar bathymetry against prior maps, and SLAM methods from ROB-340 are used with sonar and cameras for inspection of structures. Lesson 3's analysis of drift applies directly: an AUV's mapping accuracy depends on how long it goes between absolute fixes.
| Method | What it provides | Typical accuracy | Limitations |
|---|---|---|---|
| INS with DVL and depth sensor | Continuous dead-reckoned position | Drift about 0.1 to 1 percent of distance | DVL needs bottom lock; drift accumulates |
| USBL | Range and bearing from a ship | About 0.1 to 1 percent of slant range | Needs a ship nearby; accuracy falls with range |
| LBL | Position from seabed transponders | Decimeters to meters over a site | Transponders must be deployed and surveyed |
| Surface GNSS fix | Absolute position at the surface | Meters or better | Vehicle must surface; time and energy cost |
| Terrain-relative navigation | Position from matching sonar to a map | Depends on terrain and map | Needs prior bathymetry and distinctive terrain |
Communication underwater
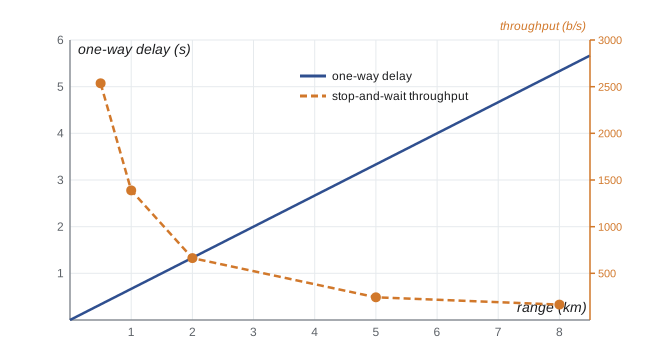
Electromagnetic waves are absorbed rapidly in seawater, so radio works only over very short ranges, except at very low frequencies with tiny bandwidths used for submarines. Optical modems using blue-green light can reach megabits per second over tens of meters in clear water. For longer ranges, acoustic communication is the only practical wireless option. Sound travels at about 1,500 m/s in seawater, roughly 200,000 times slower than light, so latency is large; absorption rises with frequency, so long-range links must use low frequencies and therefore have low bandwidth. Multipath from the surface and seabed, Doppler shifts from moving vehicles and noise from ships and waves further reduce reliable data rates. Practical acoustic modems deliver from a few hundred bits per second to tens of kilobits per second, falling with range.
# Acoustic link: latency and effective throughput of a stop-and-wait protocol
c = 1500.0                                   # speed of sound, m/s
def rate_bps(range_m):
    # illustrative modem: higher rates at short range, falling with distance
    return 15000 if range_m <= 1000 else 5000 if range_m <= 3000 else 1200
packet_bits, ack_bits = 2048, 64
for R in (500, 1000, 2000, 5000, 8000):
    r = rate_bps(R)
    t_one_way = R / c
    t_cycle = packet_bits / r + ack_bits / r + 2 * t_one_way
    eff = packet_bits / t_cycle
    print(f"range {R:5d} m: one-way delay {t_one_way:5.2f} s, raw {r:6d} b/s, "
f"stop-and-wait throughput {eff:7.0f} b/s ({eff / r:4.0%} of raw)")range 500 m: one-way delay 0.33 s, raw 15000 b/s, stop-and-wait throughput 2536 b/s ( 17% of raw) range 1000 m: one-way delay 0.67 s, raw 15000 b/s, stop-and-wait throughput 1389 b/s ( 9% of raw) range 2000 m: one-way delay 1.33 s, raw 5000 b/s, stop-and-wait throughput 663 b/s ( 13% of raw) range 5000 m: one-way delay 3.33 s, raw 1200 b/s, stop-and-wait throughput 243 b/s ( 20% of raw) range 8000 m: one-way delay 5.33 s, raw 1200 b/s, stop-and-wait throughput 165 b/s ( 14% of raw)
At long range the vehicle spends most of each cycle waiting for sound to travel, so a simple send-and-acknowledge protocol wastes most of an already small bandwidth. Underwater networks therefore use larger packets, sliding-window or broadcast protocols, careful scheduling among vehicles and heavy compression. In practice, underwater robots exchange short status messages and commands acoustically, and bulk data such as sonar images is uploaded at the surface by satellite or radio, at a dock, or after recovery. This forces high onboard autonomy, a theme lesson 11 develops for all remote field robots.
Applications
Offshore energy is the largest commercial market. ROVs support drilling and maintain subsea equipment, and AUVs survey pipeline routes and inspect lines for exposure, damage and free spans. Offshore wind adds cable and foundation inspection, scour monitoring and, increasingly, resident vehicles. Subsea telecommunications cables, which carry most intercontinental internet traffic, are surveyed and repaired with ROVs and plows. Aquaculture uses small ROVs and crawlers to inspect and clean net pens. Navies use AUVs for mine countermeasures and seabed survey, and ports use them for security inspection of hulls.
In the United States, NOAA uses gliders, uncrewed surface vehicles and profiling floats for ocean observation; since 2021 it has sent wind-powered sailing drones into Atlantic hurricanes to measure conditions at the air-sea interface. The Woods Hole Oceanographic Institution and the Monterey Bay Aquarium Research Institute operate deep-diving ROVs and AUVs, and the Ocean Observatories Initiative runs cabled and moored observatories off the Pacific Northwest and elsewhere.
Deep-sea work remains risky for robots. The hybrid vehicle Nereus, which reached the bottom of the Challenger Deep in 2009, was lost in 2014 at nearly 10,000 m in the Kermadec Trench, probably from implosion of a buoyancy sphere. Losses are a reminder that pressure housings, buoyancy materials and fault responses need rigorous testing, and that recovery plans, such as drop weights released by independent timers, are part of the design.
Rules for autonomous vessels
Uncrewed surface vessels raise questions under rules written for crewed ships, such as watchkeeping and collision regulations. In May 2026 the International Maritime Organization's Maritime Safety Committee adopted a non-mandatory International Code for the Safety of Maritime Autonomous Surface Ships (the MASS Code), effective 1 July 2026, to support an experience-building phase; a mandatory code is planned to enter into force no earlier than 1 January 2032. Small uncrewed vessels used near shore for survey or research are regulated nationally.
In the United States, the Coast Guard regulates vessel safety and navigation and has issued guidance on uncrewed and remotely operated vessels; operators should check current requirements, local navigation rules and any need for waivers before deploying an uncrewed vessel.
Common mistakes
MistakeTrimming a vehicle in a fresh-water test tank and deploying it unchanged at sea.
InsteadRecalculate and re-trim for seawater density; the difference of about 2.5 percent changes buoyancy significantly.
MistakeSizing thrusters for still-water speed only.
InsteadSize for the strongest expected current plus tether drag, remembering drag grows with the square of relative speed.
MistakePlanning to stream video from an AUV acoustically.
InsteadAcoustic links carry only status and small messages; plan for onboard autonomy and bulk data upload at the surface or dock.
MistakeAssuming DVL-aided navigation does not drift.
InsteadDrift accumulates; plan absolute fixes from USBL, LBL, surfacing or terrain matching to meet survey accuracy.
MistakeDesigning a deep vehicle without an independent recovery method.
InsteadUse positive buoyancy, drop weights on independent timers and recovery beacons so a vehicle can surface after a fault.
Summary and key terms
- Marine robots include tethered ROVs, battery-powered AUVs, gliders, profiling floats and uncrewed surface vehicles.
- Vehicles are trimmed slightly positive using syntactic foam and ballast, with buoyancy above gravity for stability.
- Drag rises with the square of speed and power with the cube, so currents and tethers dominate thruster sizing.
- Pressure rises about one atmosphere per 10 m, demanding strong housings or pressure-tolerant designs.
- Underwater navigation combines INS, DVL and depth with USBL, LBL, surfacing and terrain matching.
- Acoustic communication is slow and delayed by the 1,500 m/s speed of sound, forcing onboard autonomy.
- Applications span energy, cables, aquaculture, science and defense, and the IMO adopted a non-mandatory MASS Code in 2026.
- ROV
- Remotely operated vehicle: an underwater robot controlled through a tether that supplies power and data.
- AUV
- Autonomous underwater vehicle: an untethered, battery-powered vehicle that follows missions autonomously.
- Underwater glider
- A vehicle that moves forward slowly by changing buoyancy and gliding on wings.
- Syntactic foam
- A buoyancy material of hollow glass microspheres in resin that resists high pressure.
- Tether management system
- A cage or garage that pays out a short tether so an ROV is isolated from the motion of the main umbilical.
- Doppler velocity log
- An acoustic sensor that measures a vehicle's velocity relative to the seabed.
- USBL
- Ultra-short baseline positioning, measuring range and bearing from a ship-mounted transceiver to a beacon.
- LBL
- Long baseline positioning, using several seabed transponders to locate a vehicle.
- Acoustic modem
- A device that sends data through water as sound.
- MASS Code
- The IMO code for the safety of maritime autonomous surface ships, adopted as a non-mandatory instrument in 2026.
Practice problems
Work each problem on paper first, then reveal the answer to check.
A vehicle displaces 0.05 m³ and has a mass of 50.5 kg. Is it positively or negatively buoyant in seawater?
Show answer
Buoyant mass \( 1025 \times 0.05 = 51.25 \) kg, so it is 0.75 kg positive.
Why are AUVs streamlined while work-class ROVs are open frames?
Show answer
AUVs need low drag for efficient long-range travel on batteries; ROVs carry tools and are powered by the tether, so access matters more than drag.
If speed doubles, by what factor does propulsion power rise, ignoring efficiency changes?
Show answer
By a factor of eight, because power is drag times speed and drag scales with speed squared.
What pressure acts on a vehicle at 500 m depth?
Show answer
About \( 1025 \times 9.81 \times 500 \approx 5.0 \) MPa plus 0.1 MPa atmospheric.
How long does an acoustic message take to travel 4.5 km?
Show answer
\( 4500/1500 = 3 \) s.
Why do underwater acoustic links have low bandwidth at long range?
Show answer
Absorption rises with frequency, so long ranges require low carrier frequencies, which limit the available bandwidth.
Name two ways an AUV can correct dead-reckoning drift.
Show answer
Surfacing for a GNSS fix; USBL or LBL acoustic positioning; terrain-relative navigation.
What is a resident subsea vehicle?
Show answer
A vehicle based on the seabed at a docking station near an offshore installation, where it charges and uploads data between inspections.
Why should a deep vehicle be slightly positively buoyant?
Show answer
So it floats to the surface if power or control fails.
What is the status of the IMO MASS Code adopted in 2026?
Show answer
It is non-mandatory, effective 1 July 2026, supporting an experience-building phase before a mandatory code no earlier than 2032.
Lesson quiz · 5 questions
Score 60% or more to complete this lesson.
Create a free account to save your progress, take quizzes and earn a certificate.